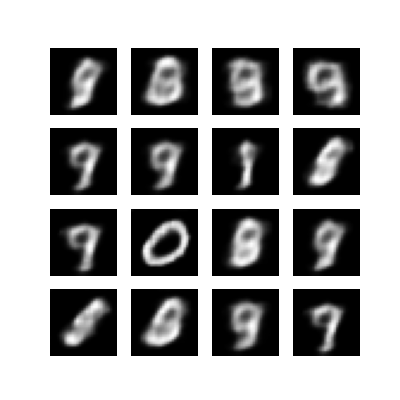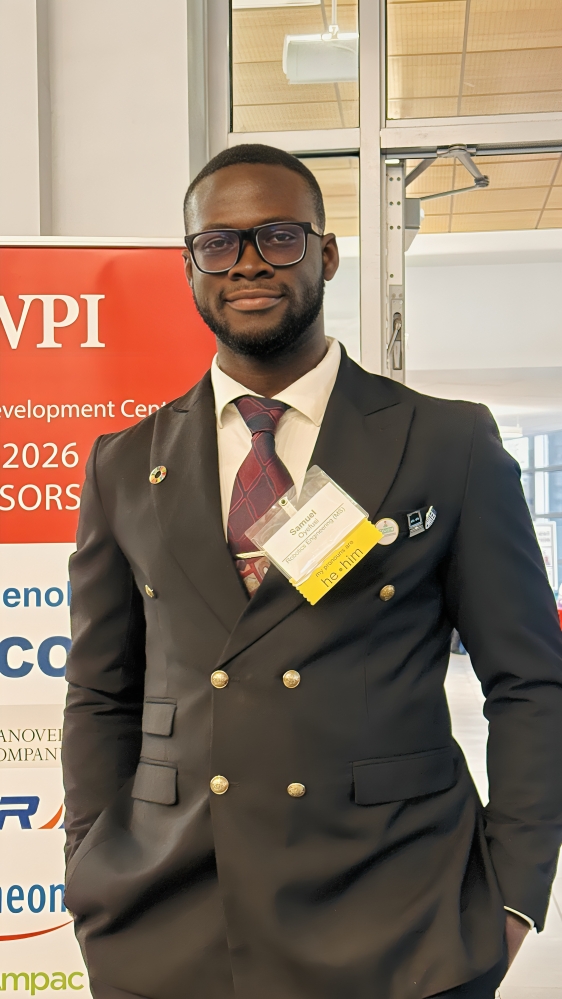
I am a PhD student in Electrical and Computer Engineering at Oakland University advised by Prof. Jared Strader. My research will focus on Robot Perception , Sensor Fusion, 3D scene understanding , Autonomy and Human-Robot Understanding.
Previously, I was an M.S. student in Robotics Engineering at Worcester Polytechnic Institute and received a First Class B.Eng. in Mechanical Engineering from Pan-Atlantic University. I hold P.E. and PMP® certifications.
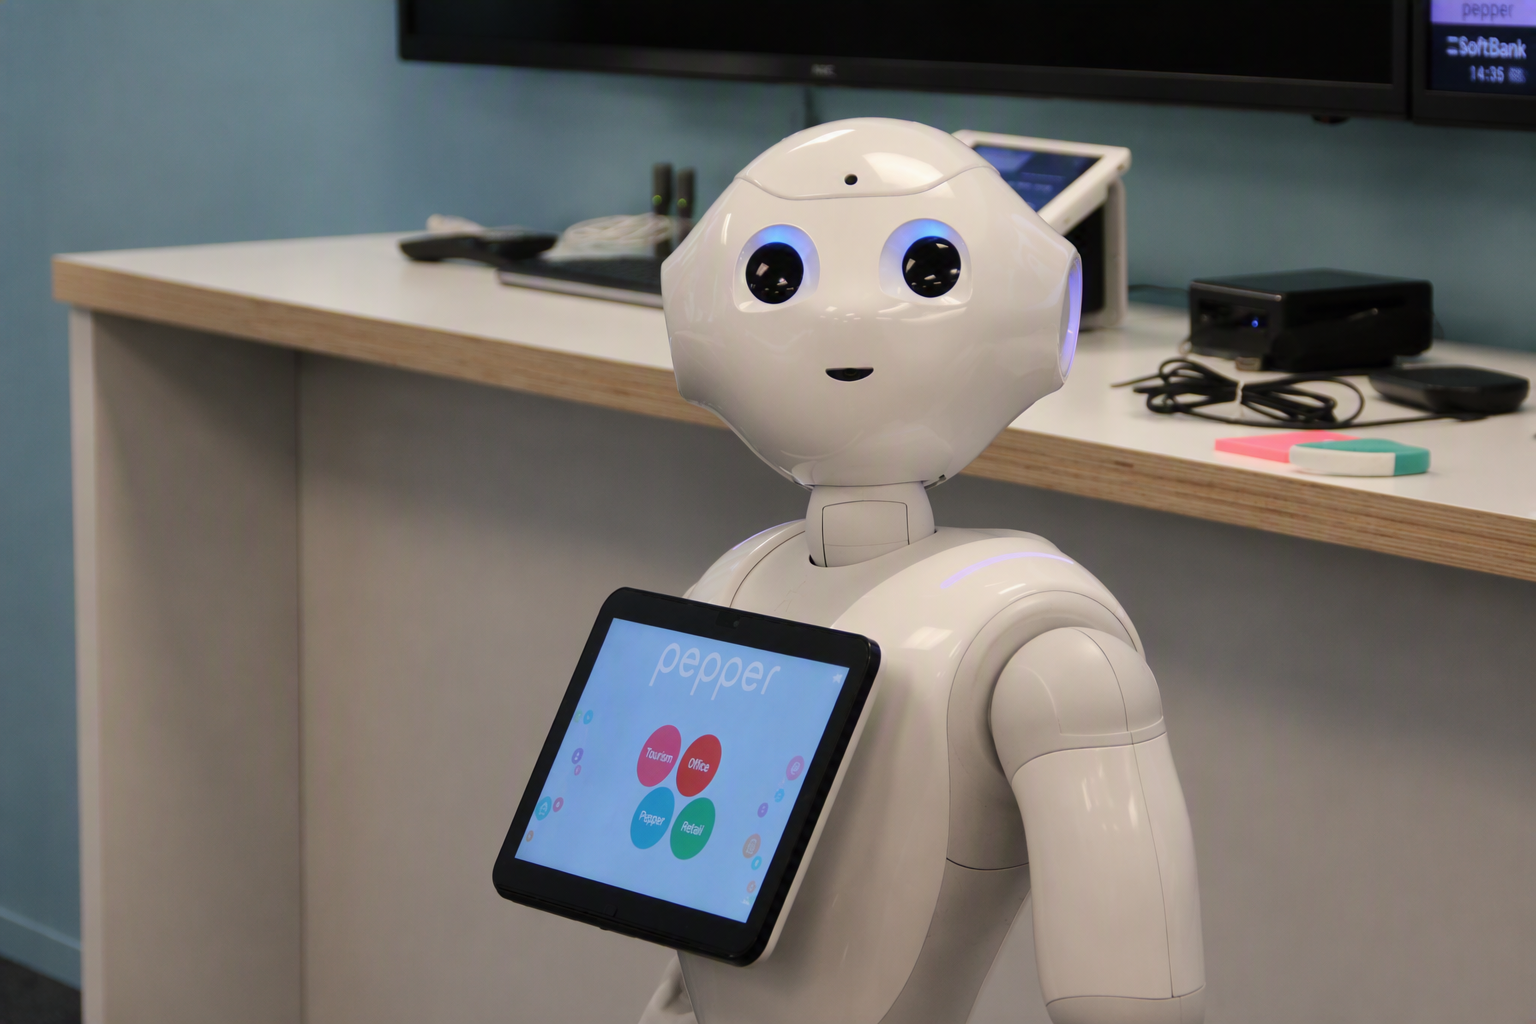
Deployed a multimodal HRI data collection system on the Pepper social robot, integrating Open AI VLM, Webcam, RealSense D435 depth sensing, tablet interaction, and audio pipelines. Ran live user experiments and debugged bridge server and sensor stacks for healthcare robot interaction research.
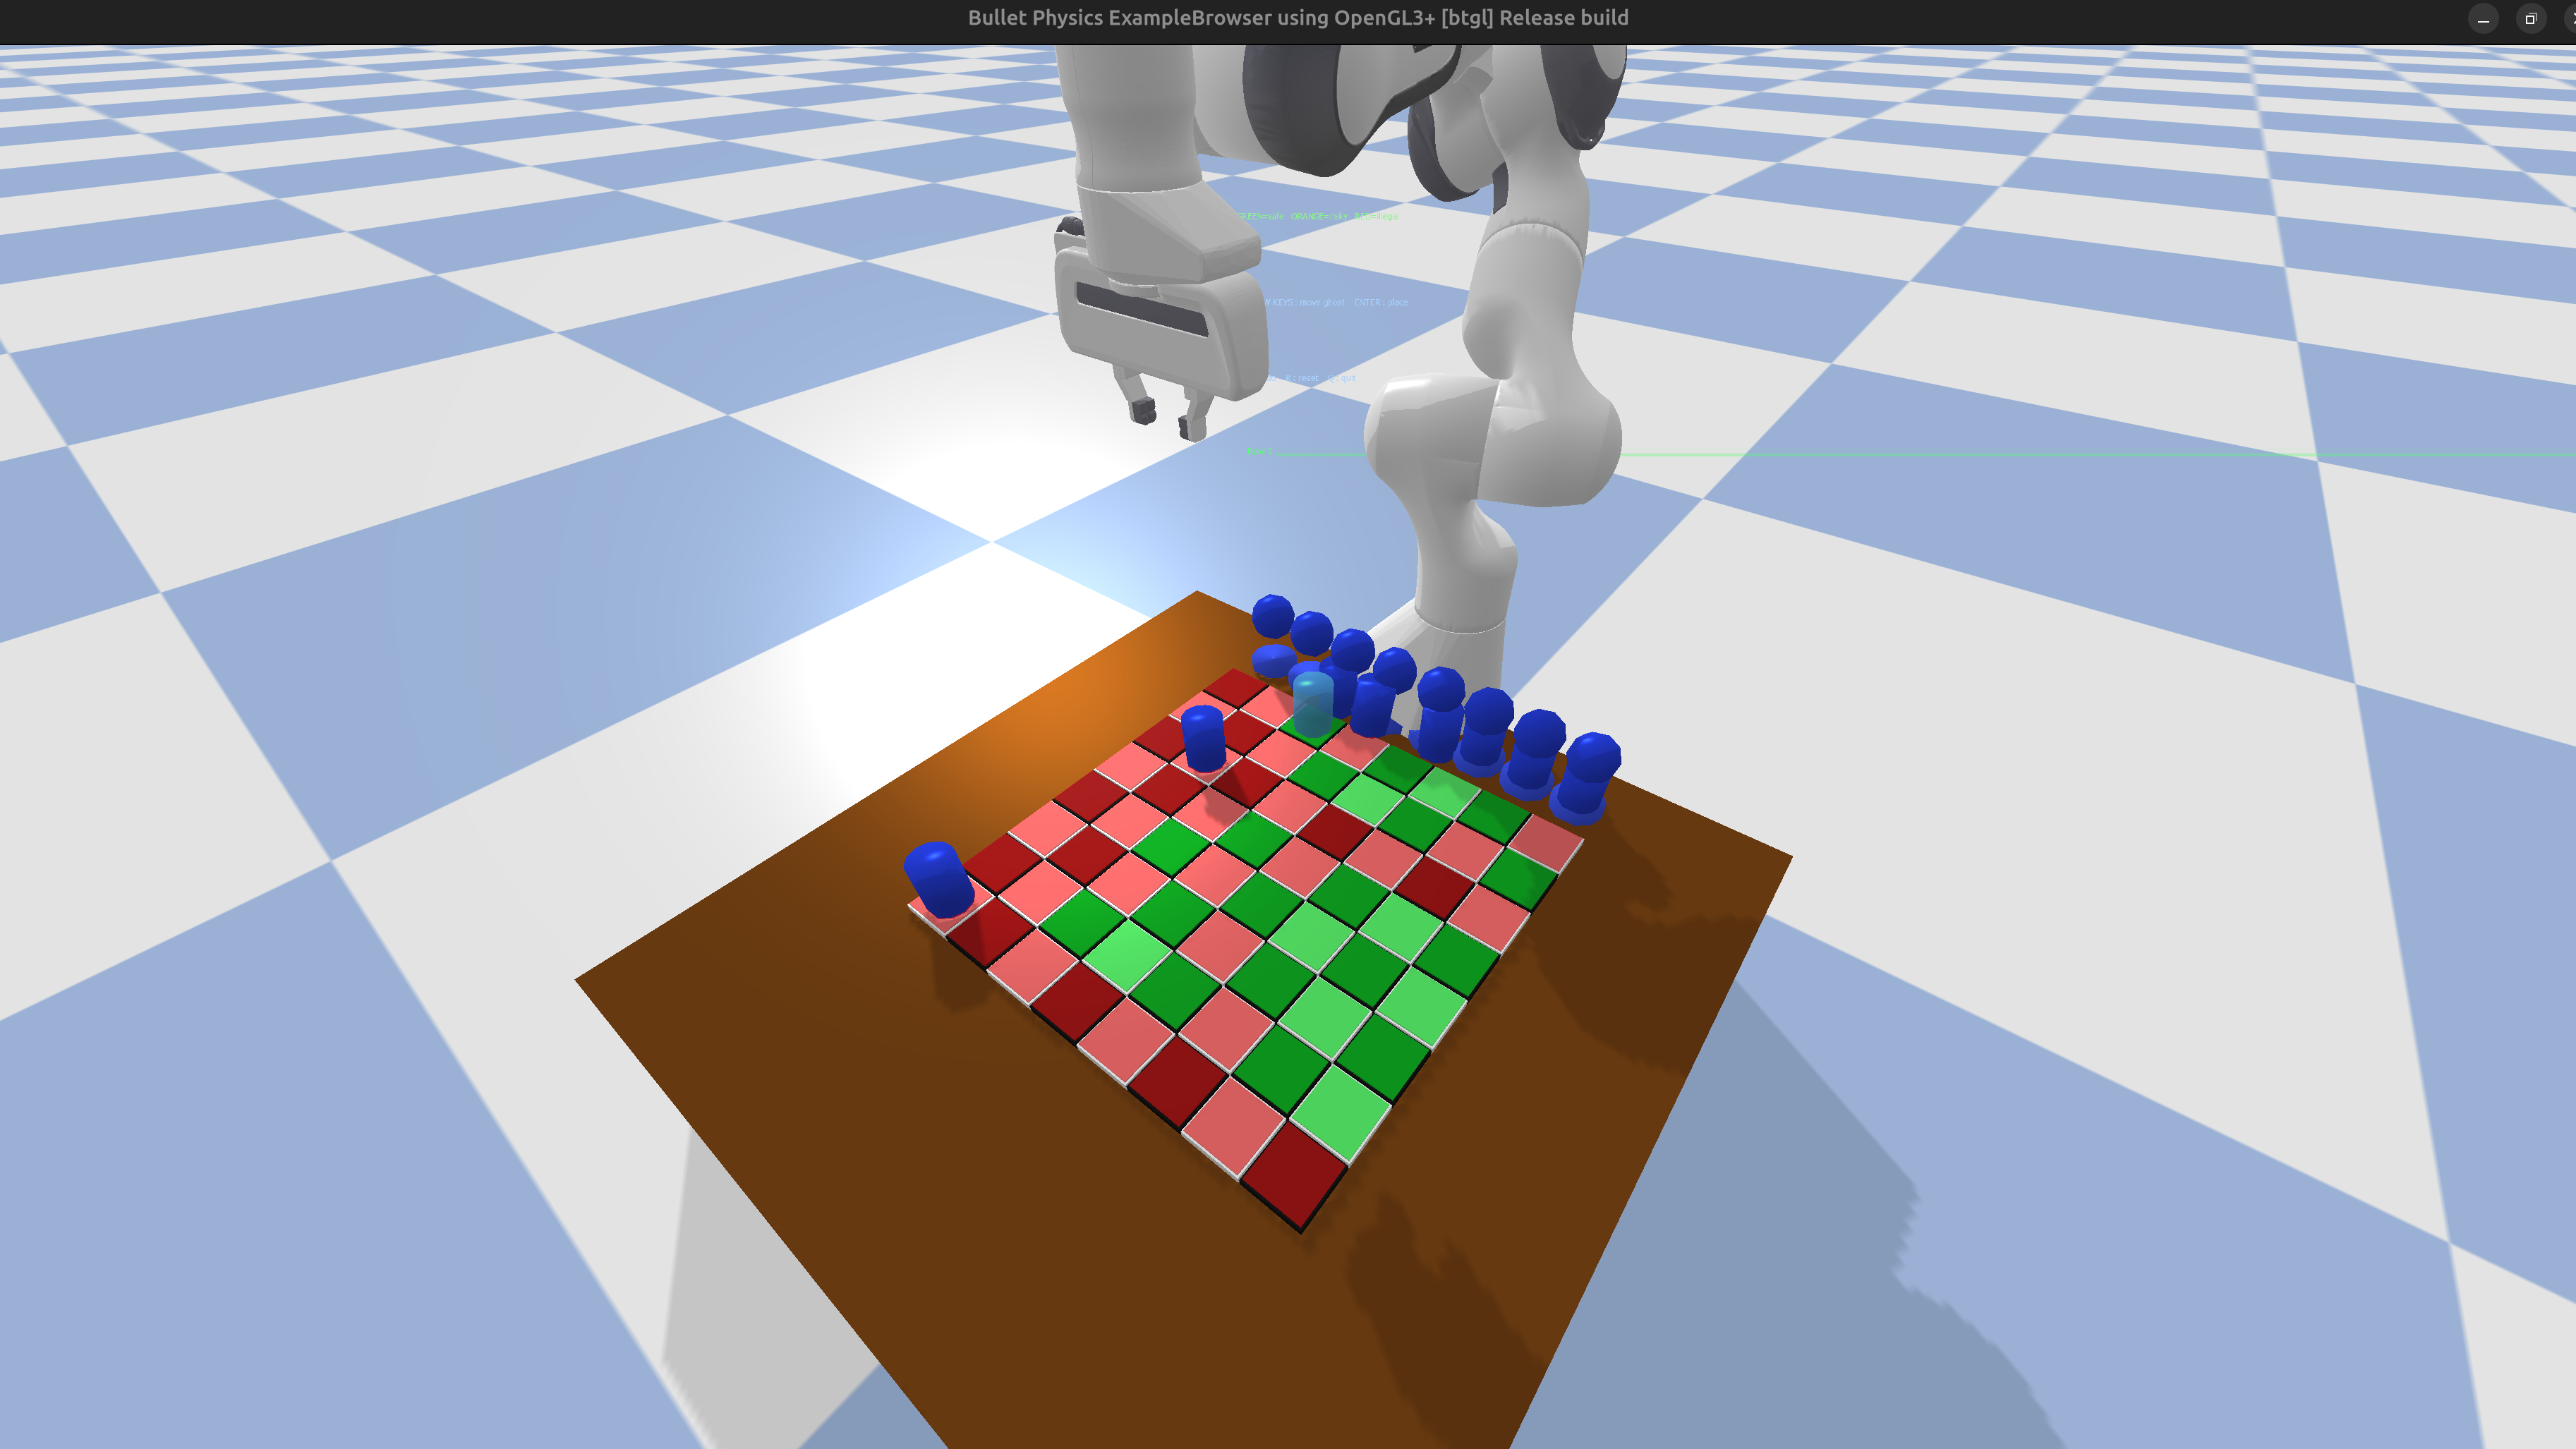
A fully simulated robotic arm pick-and-place system operated via gaze tracking and hand gesture through webcam and keyboard input. By communicating the arm's task goals and confidence thresholds to the user, the system measures preference and calibrated trust for autonomous operation against the manual alternative of direct keyboard teleoperation.
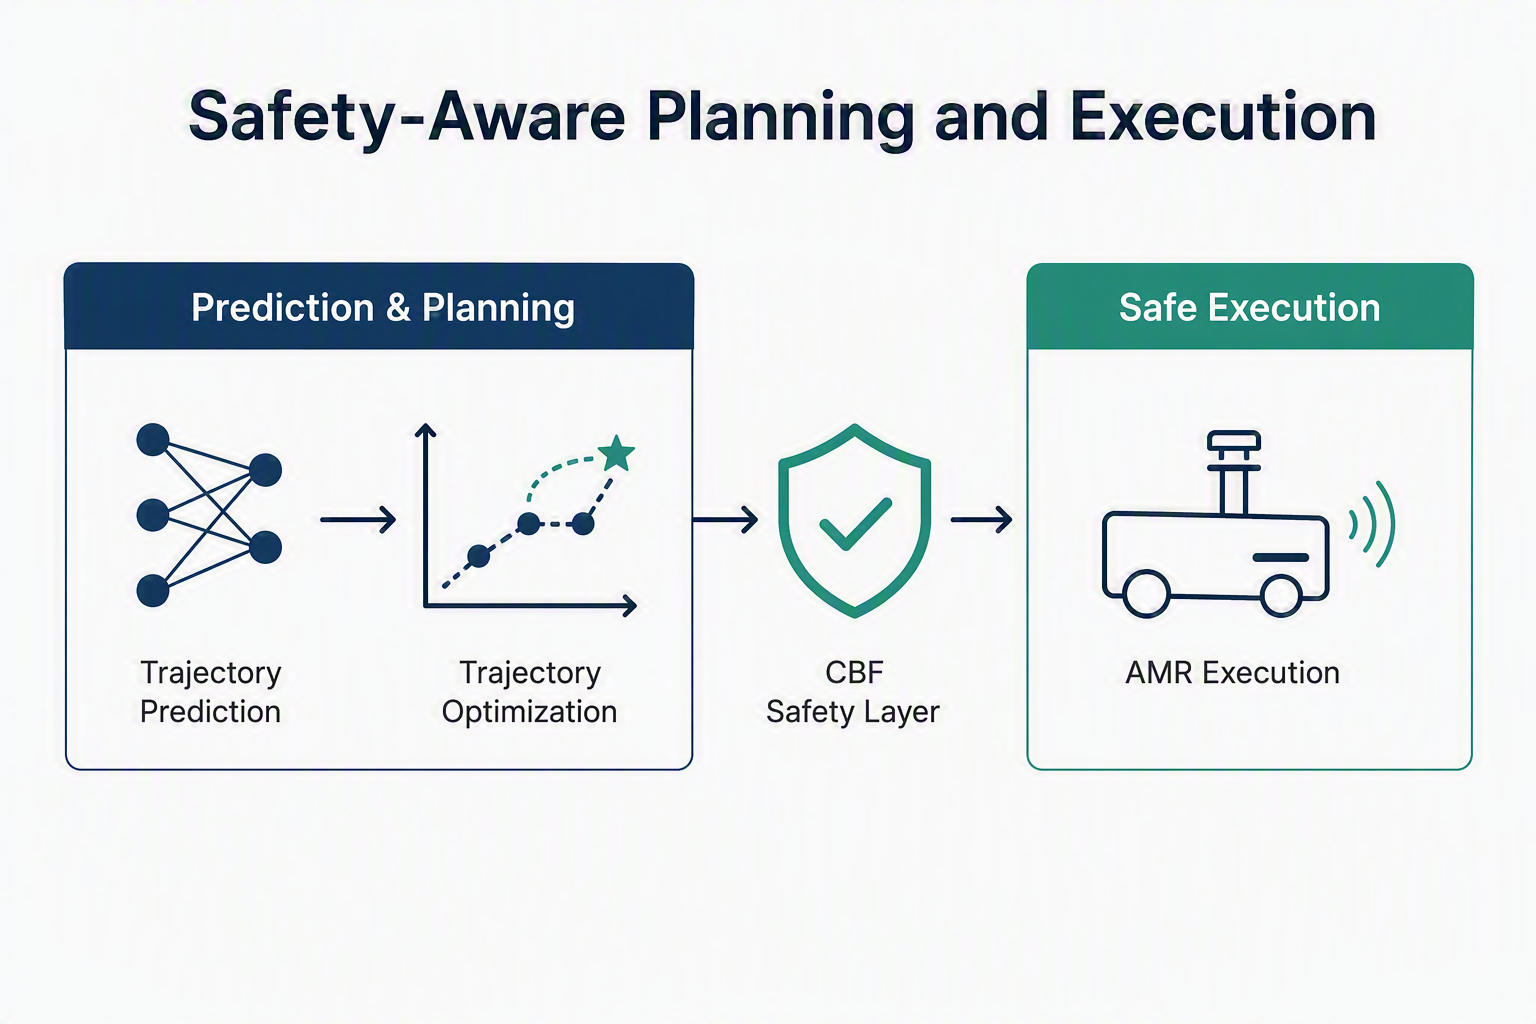
A unified framework of Control Barrier Functions, MPC, and a Transformer-based human-intent predictor enforcing hard safety constraints in human-robot collaboration. Validated on hospital AMR scenarios with formal forward-invariance proofs.
Samuel Oyefusi bolded in all entries.
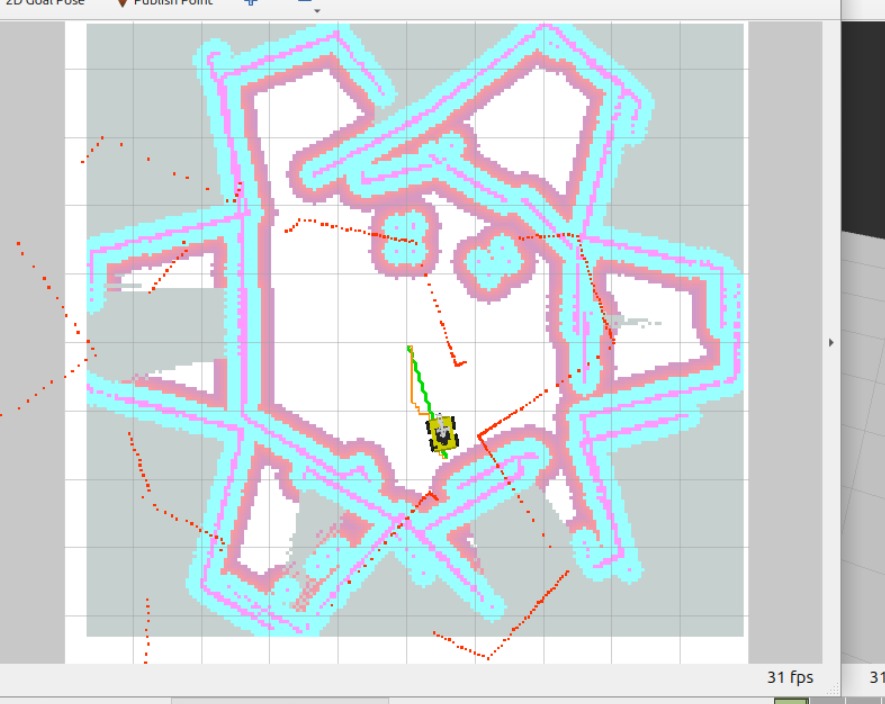
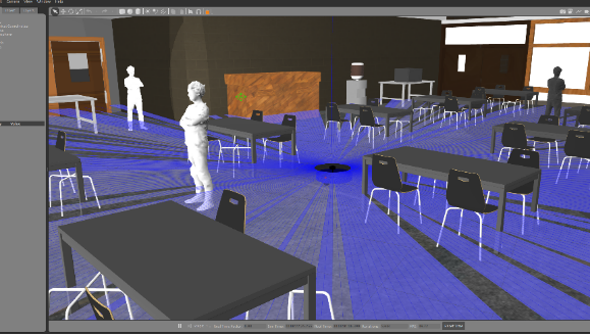
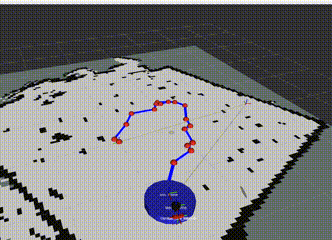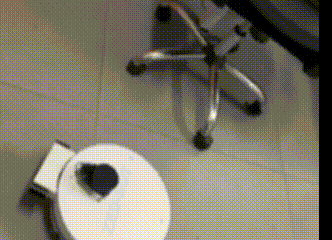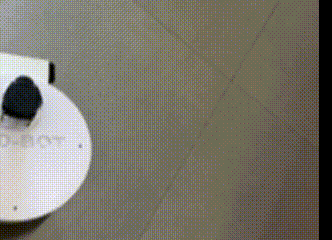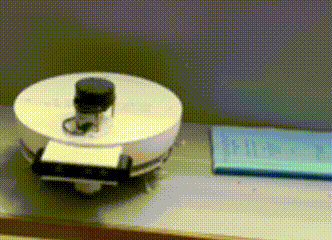
Full-stack simulation: SLAM, Nav2 A* navigation, MoveIt2 motion planning.
Hybrid A* with SAT collision detection; multi-agent PRM + A* with dynamic priority scheduling.
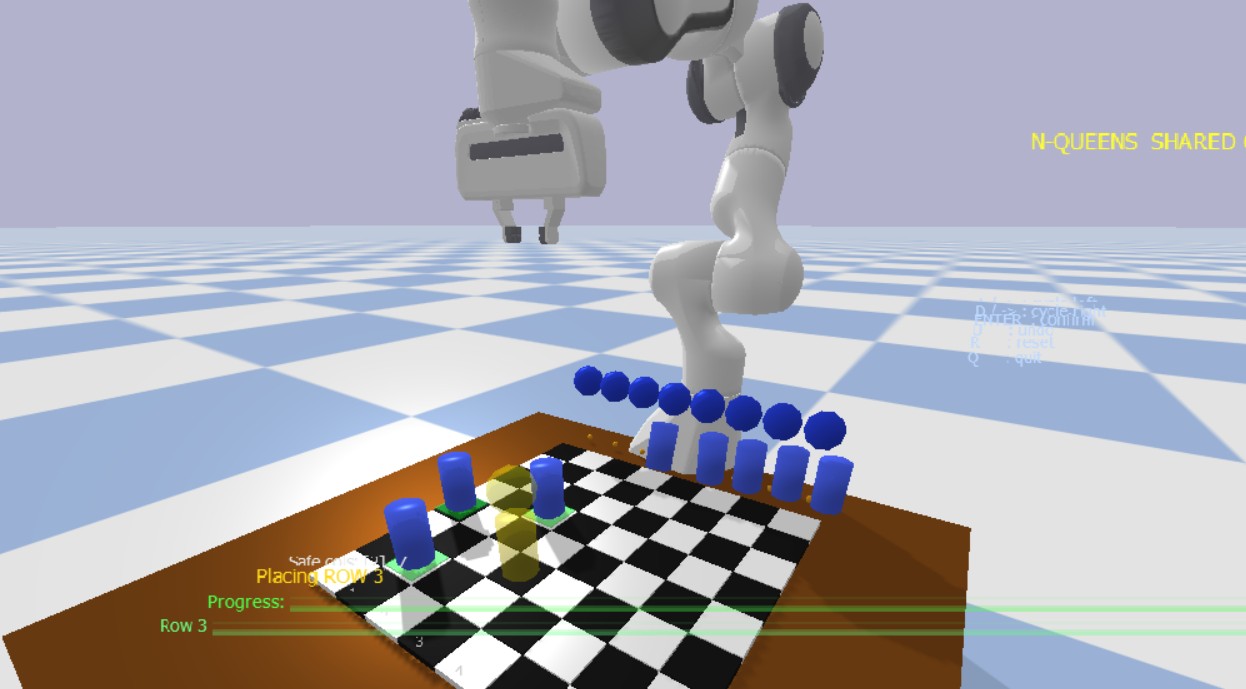
Compared supervisory vs. shared control β Tower of Hanoi and N-Queens tasks, NASA-TLX.
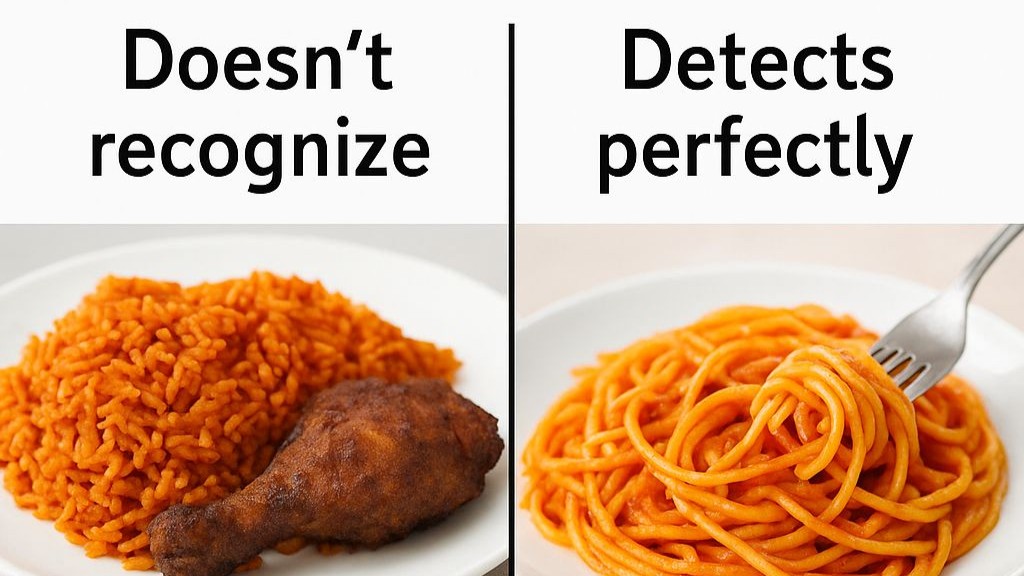
Dataset and fine-tuning pipeline addressing cultural bias in food image classifiers.
Cost-effective autonomous robot combining UVC disinfection with vacuum-cleaning coverage for indoor sanitation.
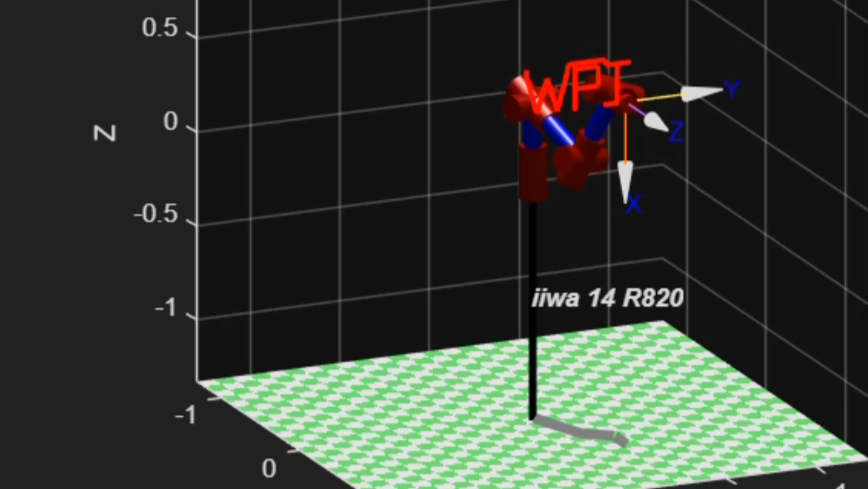
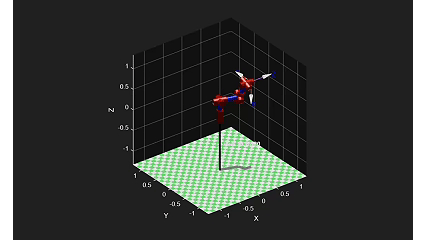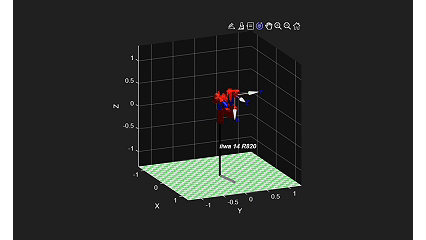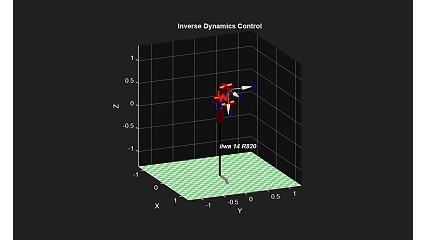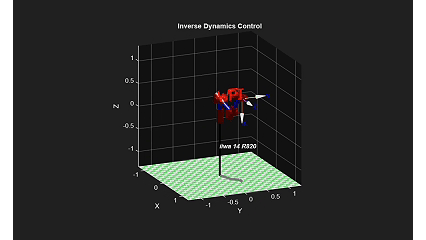
Derived and implemented the forward and inverse dynamics of the KUKA iiwa 14 R820 7-DOF manipulator in MATLAB using the Recursive Newton-Euler (RNE) algorithm.
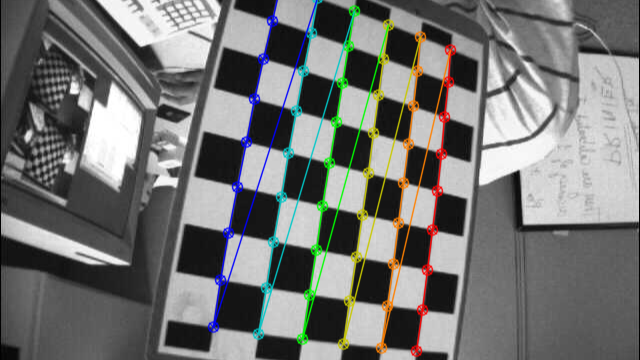
A camera-calibration system using checkerboard patterns to extract intrinsics and extrinsics, with optimization to minimize geometric error and lens-distortion modeling for high-precision, low-reprojection-error results.
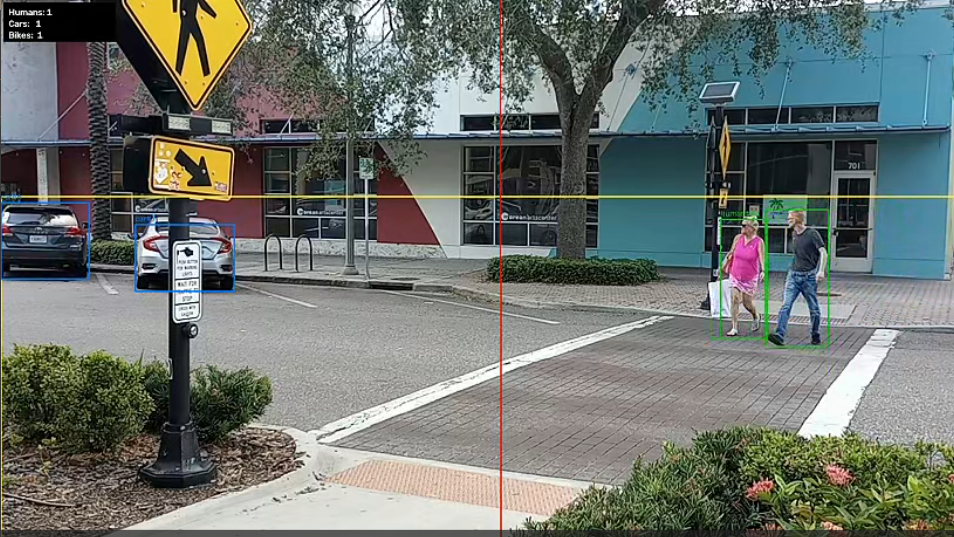
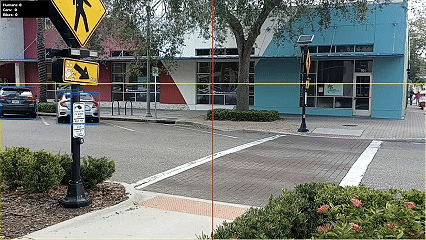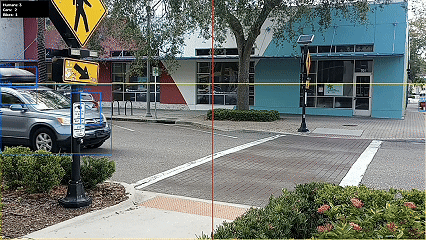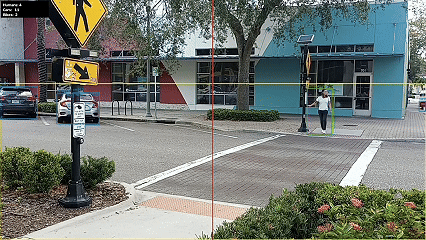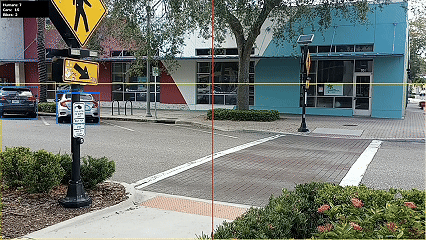
Real-time object detection pipeline that counts pedestrians, bikes, and cars in traffic video using YOLO.
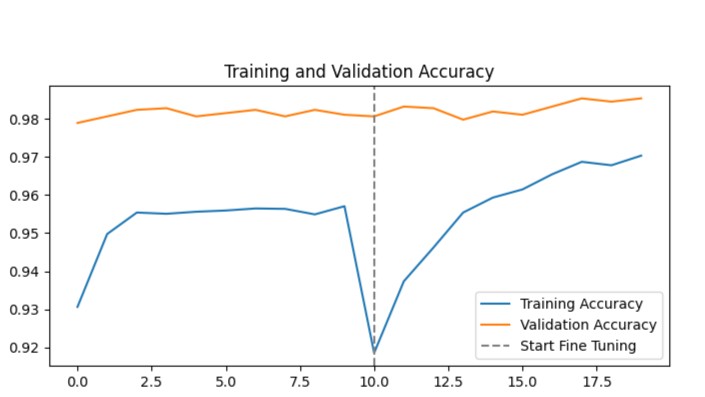
Fine-tuned a frozen, ImageNet-pretrained MobileNetV2 via feature extraction then partial unfreezing β reached ~97β98% validation accuracy.
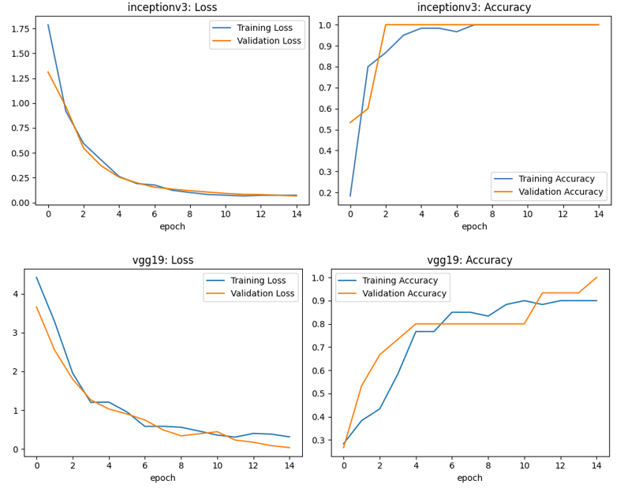
Benchmarked two backbones head-to-head on a 5-class dataset with an identical classifier and training setup β both reached 100% validation accuracy, but InceptionV3 converged in about half the epochs.
Implemented a convolutional VAE from scratch β encoder/decoder, reparameterization trick, ELBO loss β on MNIST, generating new handwritten digits by sampling from a random latent distribution.
Built a live webcam style-transfer pipeline with a fast feed-forward pretrained network, loading the SavedModel directly to work around a broken TensorFlow Hub dependency.
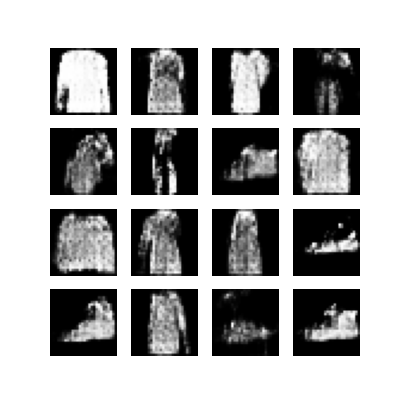
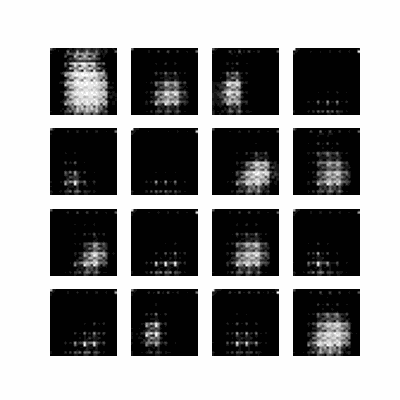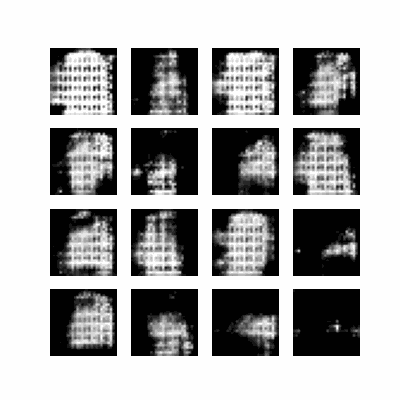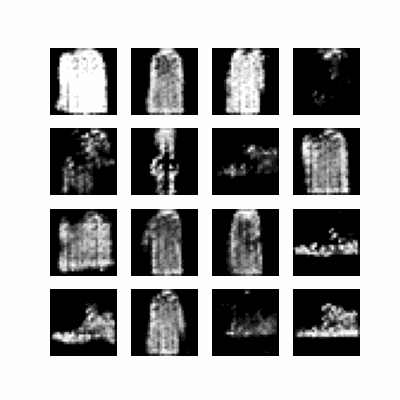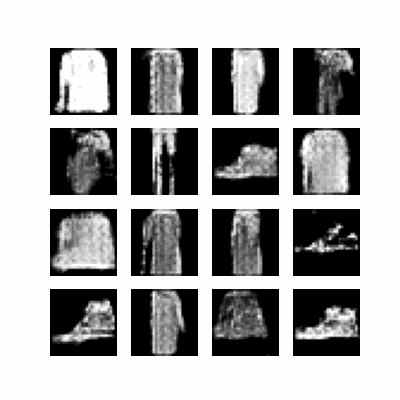
Built a Deep Convolutional GAN from scratch β transposed-conv generator and strided-conv discriminator trained adversarially on Fashion-MNIST β to synthesize realistic fake clothing images from random noise.
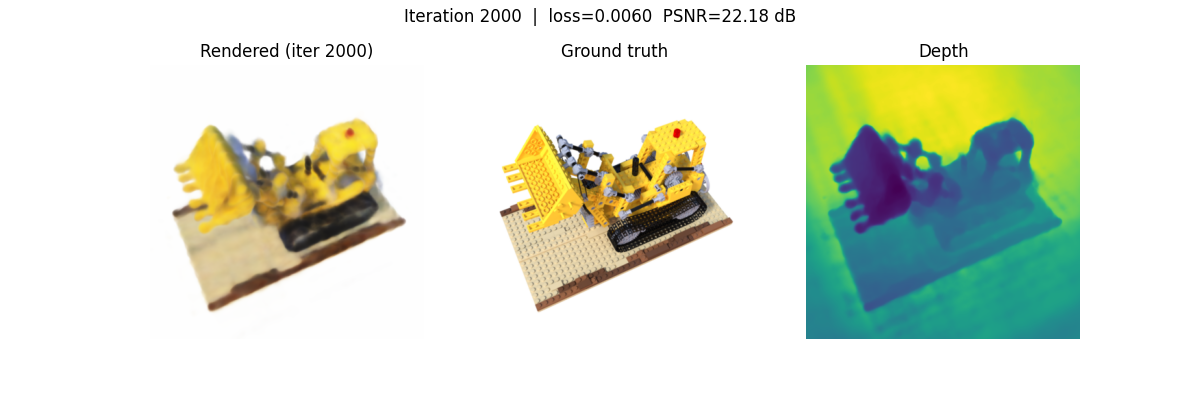
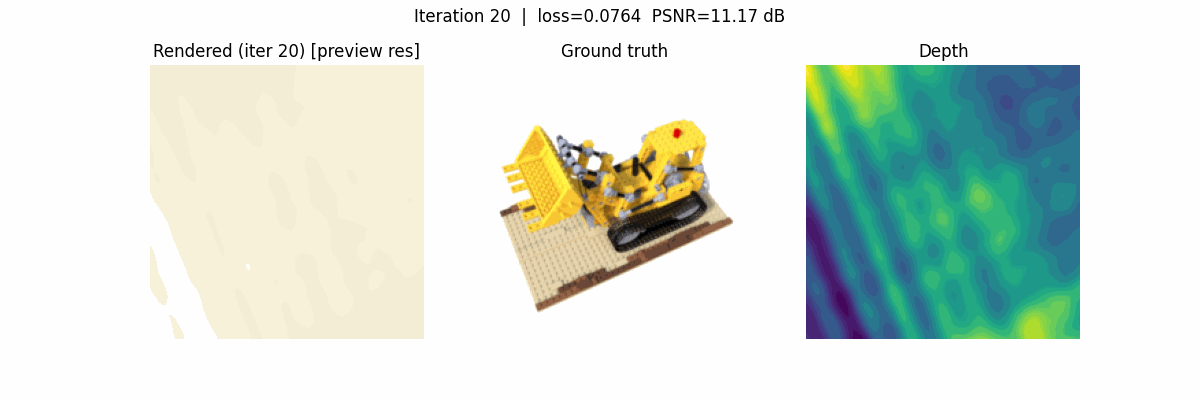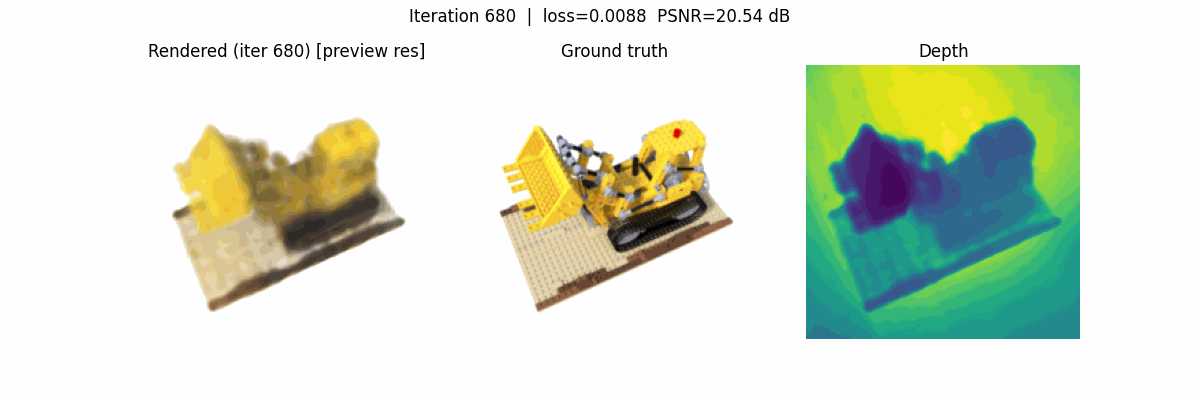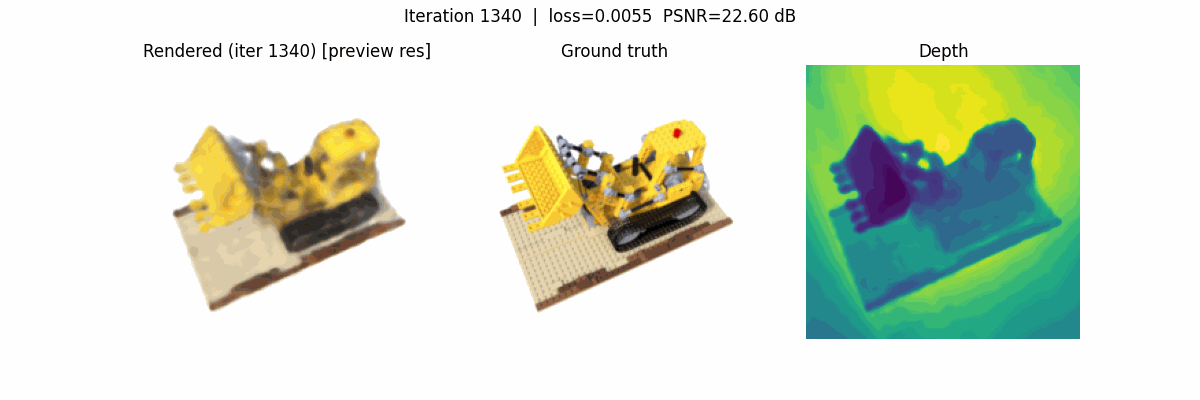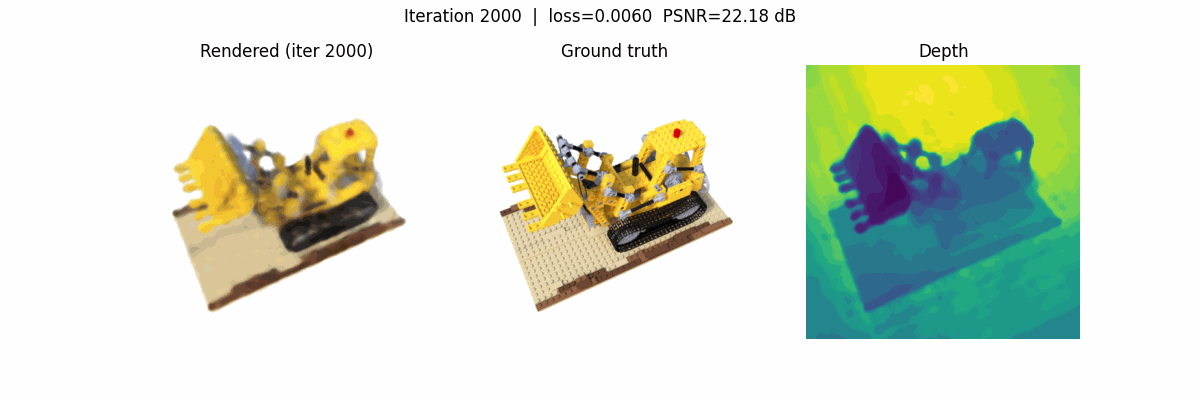
Trained a Neural Radiance Field on multi-view photos of a toy bulldozer, learning a volumetric scene representation via differentiable ray marching to render novel synthetic viewpoints of the 3D scene.